Research Knowledge Hub for 6D Object Pose Estimation
Research knowledge platform · English edition
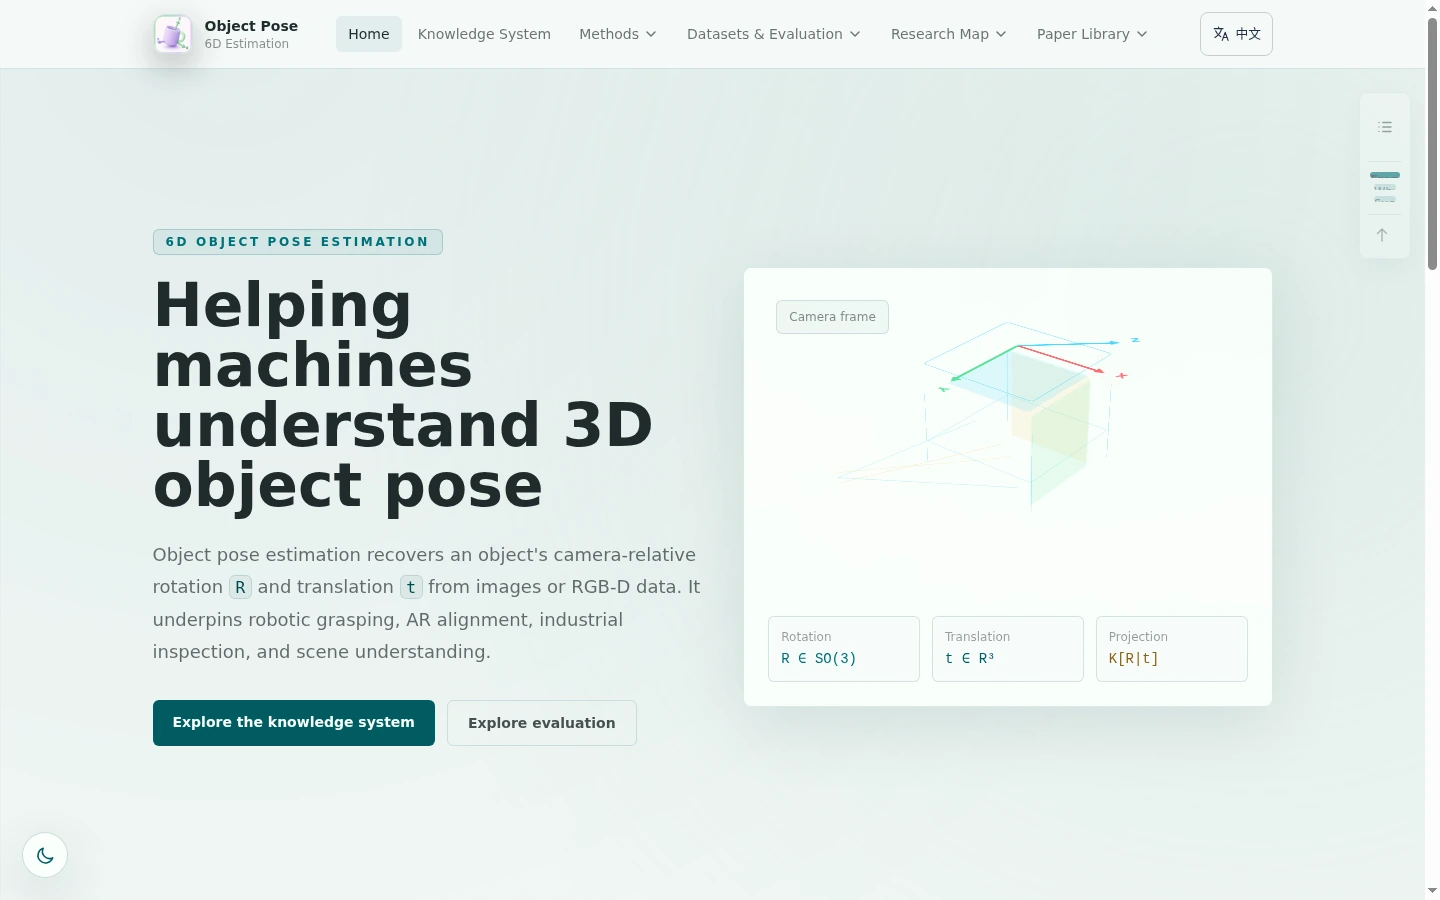
A structured reference for learning and navigating 6D object pose estimation—from coordinate frames and camera geometry to methods, benchmarks, and research papers.
From foundations to research
Understanding a pose-estimation paper often means moving between geometry, model design, datasets, and evaluation protocols. This hub brings those pieces together in one place, supporting both a guided learning path and quick reference during research.
Geometry, methods, and evaluation
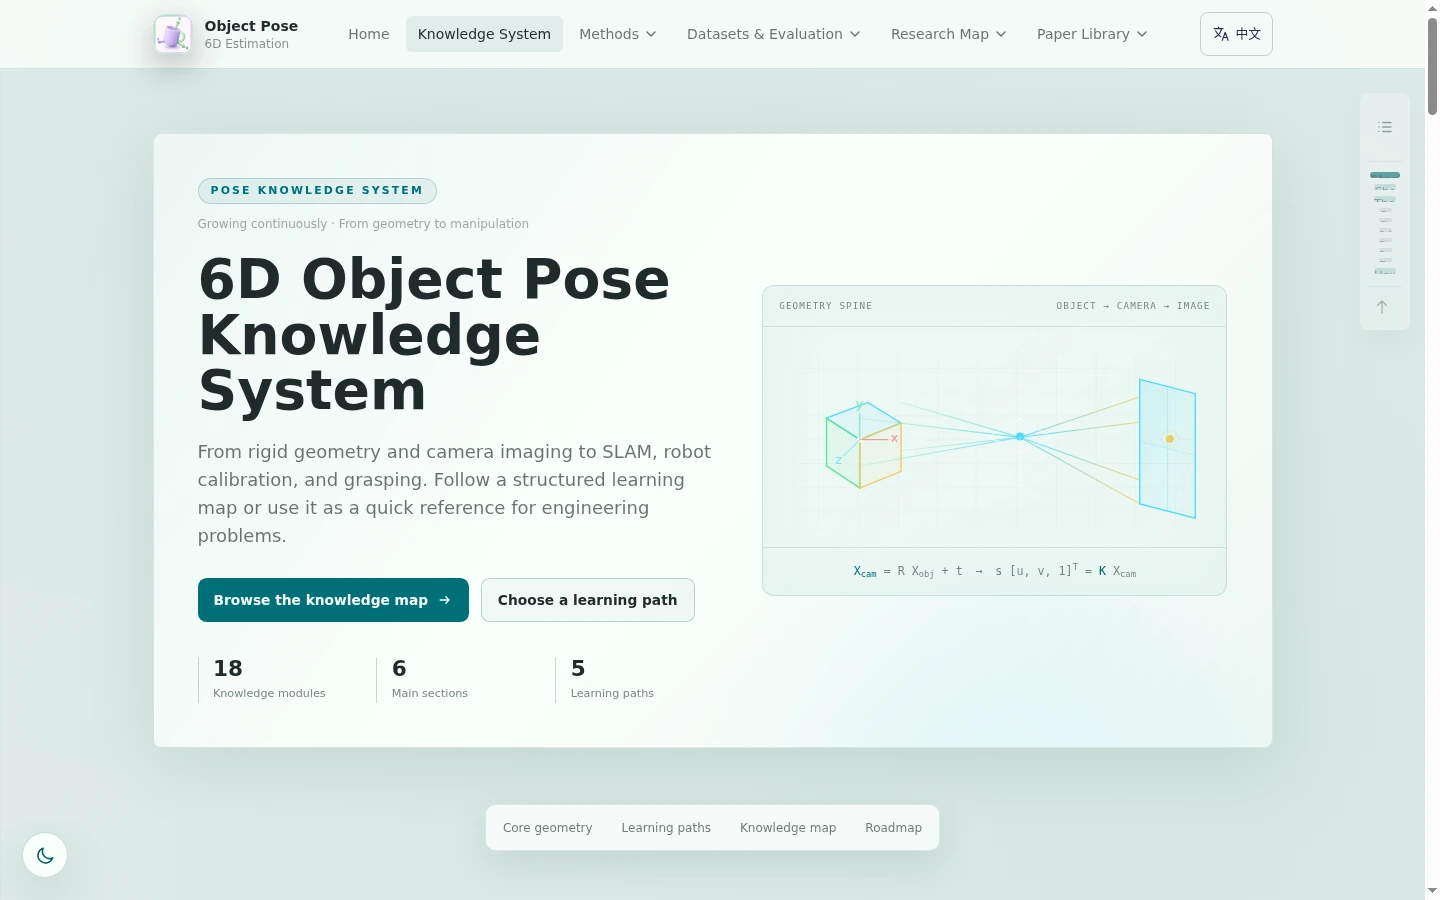
The knowledge system connects rigid transformations, camera projection, and PnP with SLAM, robot calibration, and manipulation. Geometric diagrams help relate object coordinates, camera coordinates, and image pixels.
Build geometric intuition
Follow structured learning paths through coordinate frames, camera models, and pose recovery.
Compare method families
Navigate templates, keypoints, correspondences, refinement, and foundation-model approaches by their inputs and assumptions.
Read results in context
Connect datasets with metrics such as ADD, ADD-S, VSD, and BOP Average Recall, including symmetry and evaluation thresholds.
Find and connect research papers
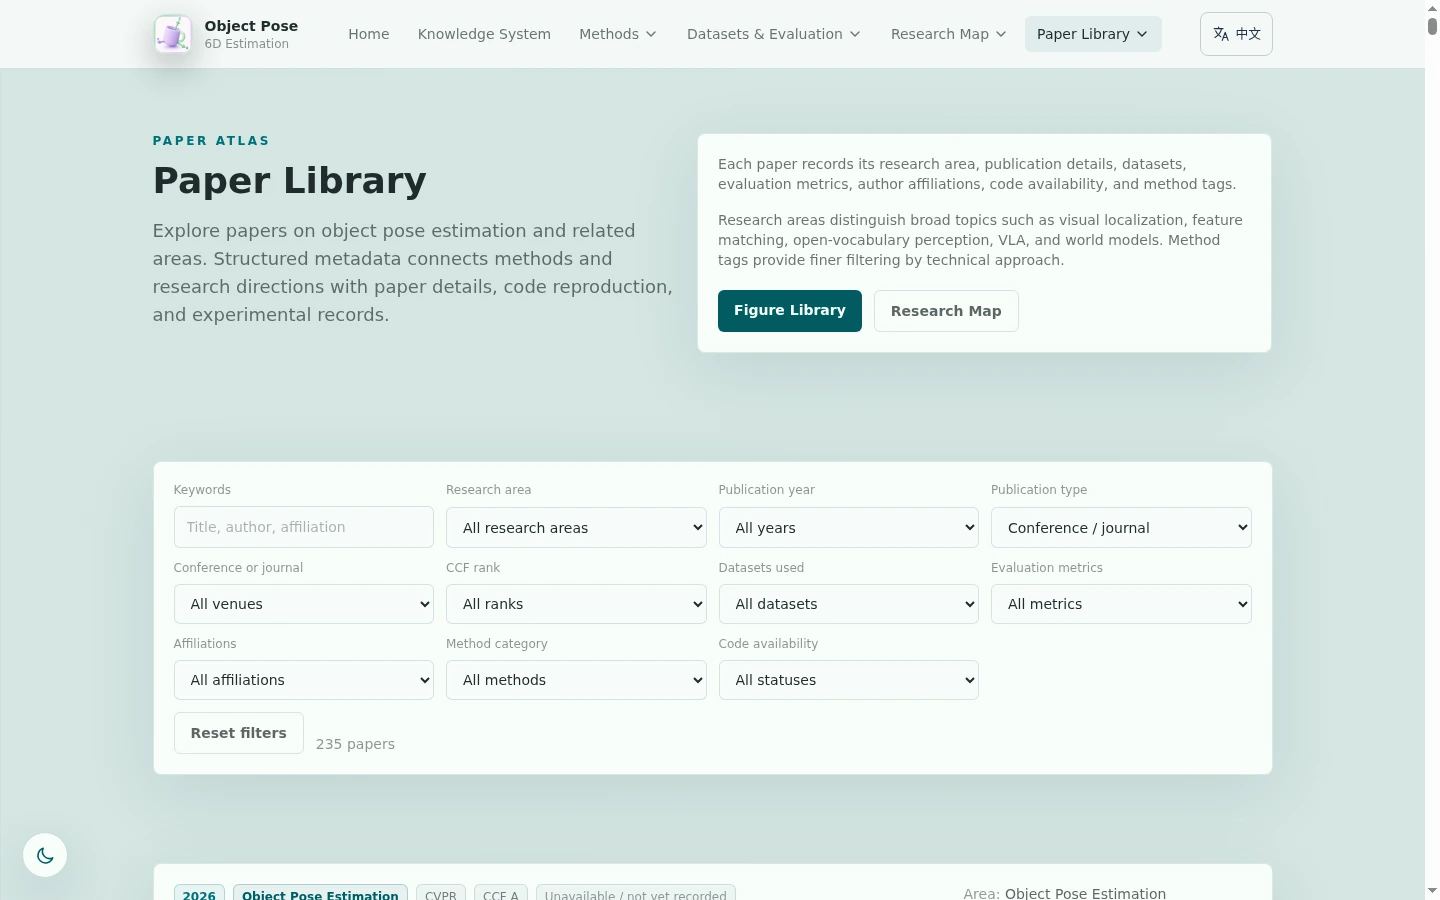
A searchable paper library organizes work by research area, publication year, venue, dataset, evaluation metric, and method category. Paper pages bring together structured metadata, source links, and reading notes.
The research map connects 6D pose with feature matching, open-vocabulary perception, 3D representations, and embodied AI, helping readers follow related ideas across topics.